Perception and Modeling
The lab builds perception methods aimed at inferring human mental and emotional states for collaborative robotics, going beyond conventional computer vision. This includes designing model representations of human behavior and cognitive state that remain trainable on datasets that are small, noisy, or incomplete.
← All research areas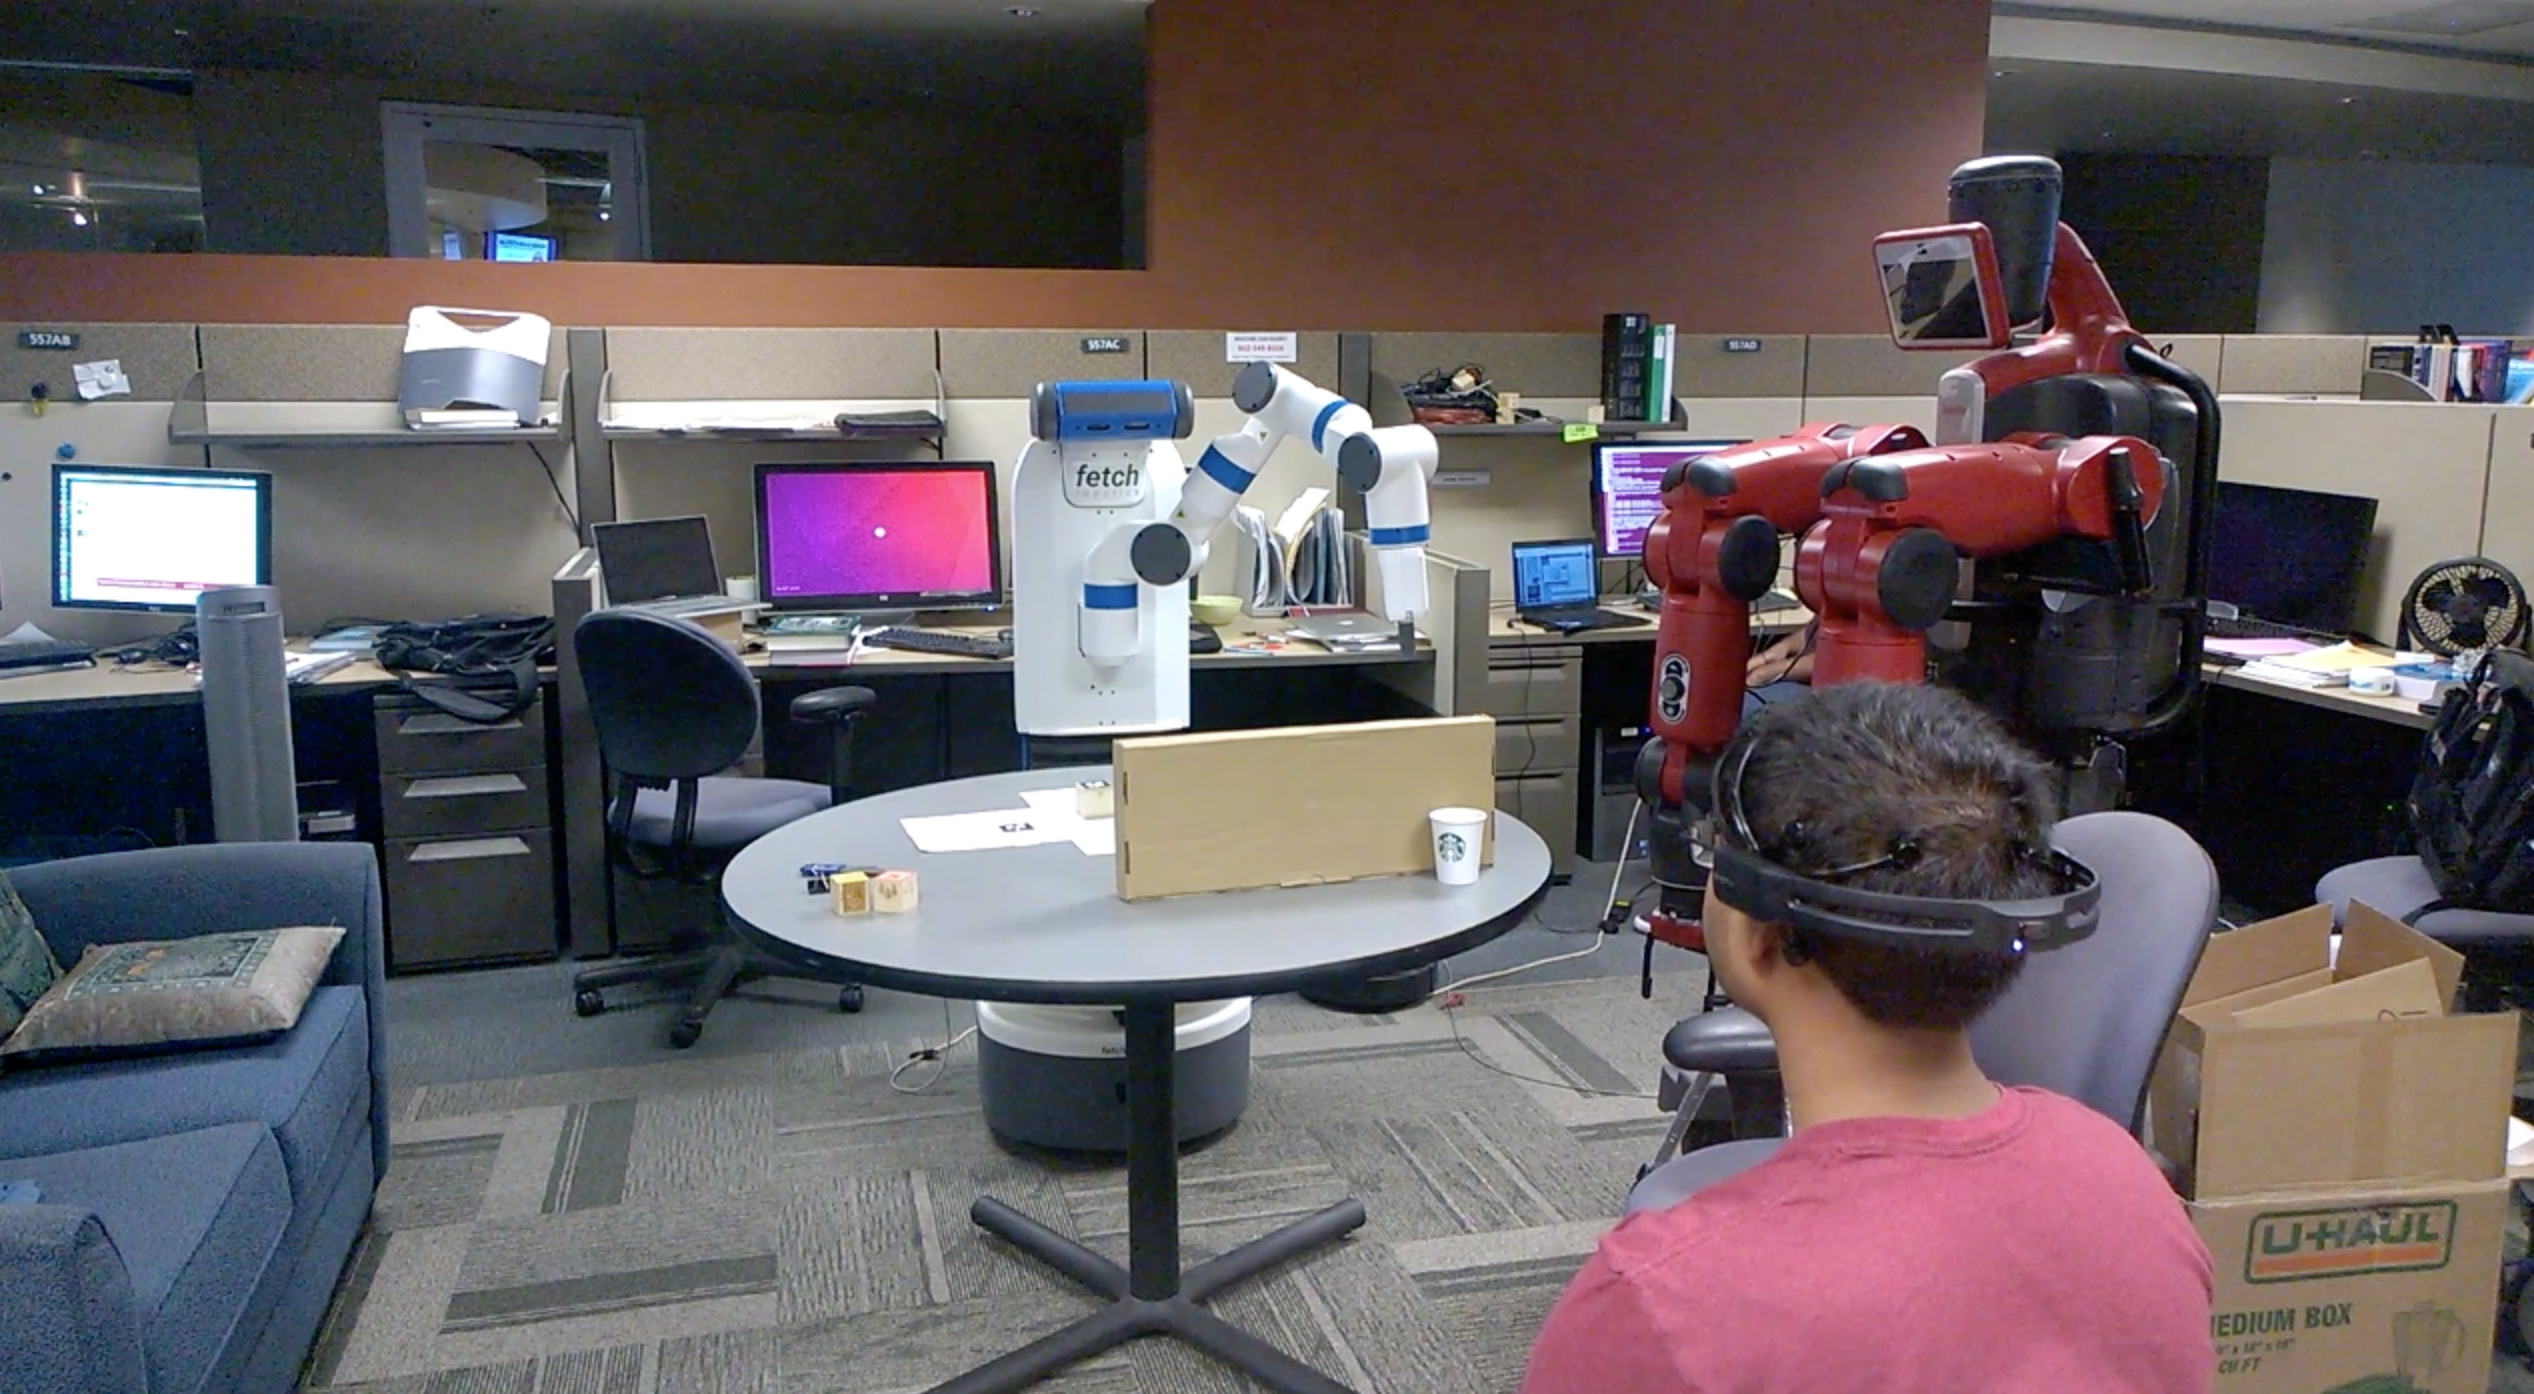
Related work
-
Perceiving Human Mental State for Collaboration Featured
Model representations of human behavior and cognitive state, trainable on the small, noisy datasets that real collaborative settings produce.
Effective human-robot collaboration depends on the robot having some working model of what its human teammate is thinking, intending, and feeling. This project develops model representations of human behavioral and mental state that remain robust when trained on limited, noisy, or incomplete data (the norm rather than the exception in real deployment settings), rather than relying on large curated datasets and conventional computer vision alone.